Here are some sites that I found that are useful for infared tracking:
http://massftc.org/robotc/
http://web.mit.edu/roll/website/MITiBot/2875downloads.html
http://botbench.com/blog/robotc-driver-suite/
http://botbench.com/downloads/ROBOTC_driver_tutorial.pdf
http://www.chiefdelphi.com/forums/showthread.php?t=79248
Enjoy.
Edit 30th post :D
Tuesday, December 4, 2012

Saturday, November 17, 2012
November 11th Meeting

Wednesday, November 14, 2012


Meetings from October 16th to November 13th
Sorry we have slipped away from our blog postings, this will not happen again and we are sorry for the inconvenience.

Over the past month, we made great achievements in our robot. To begin with, we made a ring gripping device that is very effective, thanks to a collaborative effort between Jared and Ian. I have worked on designing n infrared detection system with code that provides the widest field-of-view, I have been making decent progress solving this. Jaret has been working primarily on tackling the end game challegnes, and has built a ramp prototype with Etienne.

Over the past month, we made great achievements in our robot. To begin with, we made a ring gripping device that is very effective, thanks to a collaborative effort between Jared and Ian. I have worked on designing n infrared detection system with code that provides the widest field-of-view, I have been making decent progress solving this. Jaret has been working primarily on tackling the end game challegnes, and has built a ramp prototype with Etienne.
Saturday, October 13, 2012
October 13th Meeting
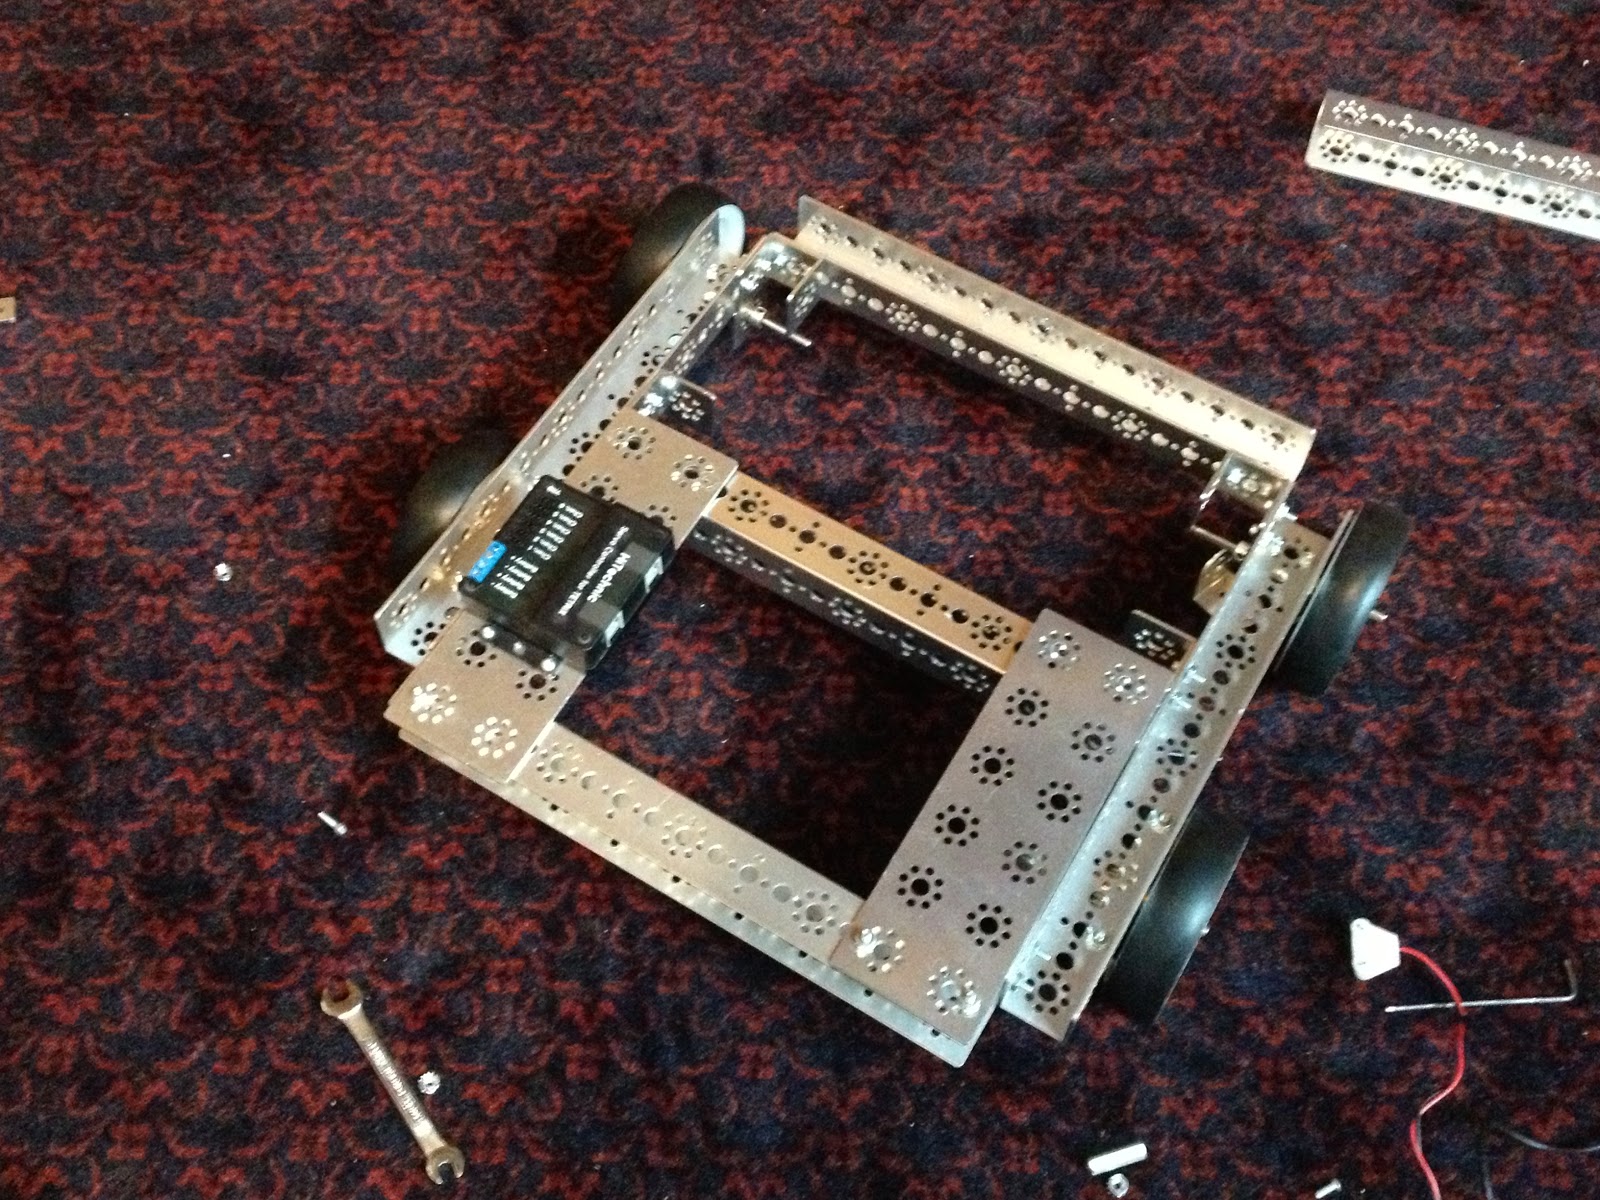 |
| Ben's secondary robot. |
#pragma config(Hubs, S1, HTMotor, HTServo, none, none)
#pragma config(Sensor, S1, , sensorI2CMuxController)
#pragma config(Sensor, S2, HTIRS2, sensorI2CCustom)
#pragma config(Motor, motorA, spinner, tmotorNXT, PIDControl, encoder)
#pragma config(Motor, mtr_S1_C1_1, Wheel_Left, tmotorTetrix, openLoop, reversed)
#pragma config(Motor, mtr_S1_C1_2, Wheel_Right, tmotorTetrix, openLoop)
#pragma config(Servo, srvo_S1_C2_1, servo1, tServoNone)
#pragma config(Servo, srvo_S1_C2_2, servo2, tServoNone)
#pragma config(Servo, srvo_S1_C2_3, servo3, tServoNone)
#pragma config(Servo, srvo_S1_C2_4, servo4, tServoNone)
#pragma config(Servo, srvo_S1_C2_5, servo5, tServoNone)
#pragma config(Servo, srvo_S1_C2_6, servo6, tServoNone)
//*!!Code automatically generated by 'ROBOTC' configuration wizard !!*//
#include "drivers/HTIRS2-driver.h"
task spin();
task main ()
{
int _dirDC = 0;
int _dirAC = 0;
int _distDCsum = 0;
int dcS1, dcS2, dcS3, dcS4, dcS5 = 0;
int acS1, acS2, acS3, acS4, acS5 = 0;
int total = 0;
int count = 0;
int combinedavg = 0;
nxtDisplayTextLine(1, "Display Error!");
StartTask(spin);
while (true)
{
_dirDC = HTIRS2readDCDir(HTIRS2);
if (_dirDC < 0)
break;
_dirAC = HTIRS2readACDir(HTIRS2);
if (_dirAC < 0)
break;
if (!HTIRS2readAllDCStrength(HTIRS2, dcS1, dcS2, dcS3, dcS4, dcS5))
break;
if (!HTIRS2readAllACStrength(HTIRS2, acS1, acS2, acS3, acS4, acS5 ))
break;
_distDCsum = (dcS1 + dcS2 + dcS3 + dcS4 + dcS5);
ClearTimer(T1);
while(time1[T1] < 1600)
{
total = total + _dirDC;
if (_dirDC != 0)
{
count = count + 1;
}
}
int _dirAvgSpin = 0;
_dirAvgSpin = abs(total / count);
combinedavg = (combinedavg + _dirAvgSpin) / count;
nxtDisplayTextLine(4, "DistAvg: %d", _dirAvgSpin);
nxtDisplayTextLine(3, "AverageAvg: %d", combinedavg);
}
}
task spin()
{
while(true)
{
motor[spinner] = 15;
wait1Msec(800);
motor[spinner] = -15;
wait1Msec(800);
}
}
Saturday, October 6, 2012
Meeting on the sixth of October
Today, we worked on many things. Some of those things were Ian's ring picker lift thingy. Ben worked on refining the weight machine to see if the ring was a weighted ring or if it was not. A-t-in worked on making the wheel assembly a lot better. He got rid of the annoying squeak that was bugging all of us. He also tried and made it not slip, which it does when it turns very quickly and sharply. Tyler worked on the autonomous program and also helped me work on the ramp. We have an idea to just lift the robot 1'' because that seems to be the most efficient way to do it. You score 30 points for the first inch and then only 5 points for every subsequent inch. Also I worked on my program to enhance the readability of it.
Subscribe to:
Posts (Atom)